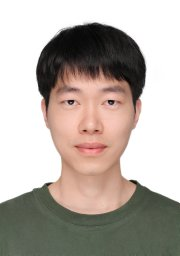
Portrait of Jianxin Huang

Jianxin Huang

Embodied AI Researcher at Unitree Robotics

I work on the continued pre-training of vision-language models (VLM), vision-language-action models (VLA), and world-action models (WAM), with a focus on embodied intelligence and general-purpose robots.

About

I obtained my M.Eng. from the College of Control Science and Engineering at Zhejiang University in 2023 and my B.Eng. in Automation from Harbin Institute of Technology in 2019. My current research primarily focuses on Embodied AI. I am also interested in deep stereo matching, feed-forward 3D reconstruction, and video world models.

Selected Work

All publications
2026

UnifoLM-WLA-1.0

General-Purpose Humanoid Robot Foundation Model 🔥

UnifoLM-WLA-1.0 is Unitree Robotics' comprehensively upgraded, next-generation general-purpose humanoid robot foundation model with 6B parameters. Trained on approximately 2,500 hours of high-quality real-robot data, a single model coordinates 64 tasks spanning desktop manipulation and whole-body manipulation.

World model · Vision-language-action · Whole-body control

Project page
2026

UnifoLM-VLA-0

A Vision-Language-Action Model for General-Purpose Manipulation

UnifoLM-VLA-0 is a Vision–Language–Action (VLA) large model in the UnifoLM series, designed for general-purpose humanoid robot manipulation.

Vision-language-action · Robot manipulation

Project page
Gaussian-LIC2 SLAM demonstration2026

Gaussian-LIC2: LiDAR-Inertial-Camera Gaussian Splatting SLAM

The International Journal of Robotics Research (IJRR), 2026 🔥

Xiaolei Lang, Jiajun Lv, Kai Tang, Laijian Li, Jianxin Huang, Lina Liu, Yong Liu, and Xingxing Zuo

We present the first photo-realistic LiDAR-Inertial-Camera Gaussian Splatting SLAM that jointly addresses visual quality, geometric accuracy, and real-time performance.

Gaussian Splatting · LiDAR-inertial-camera · SLAM

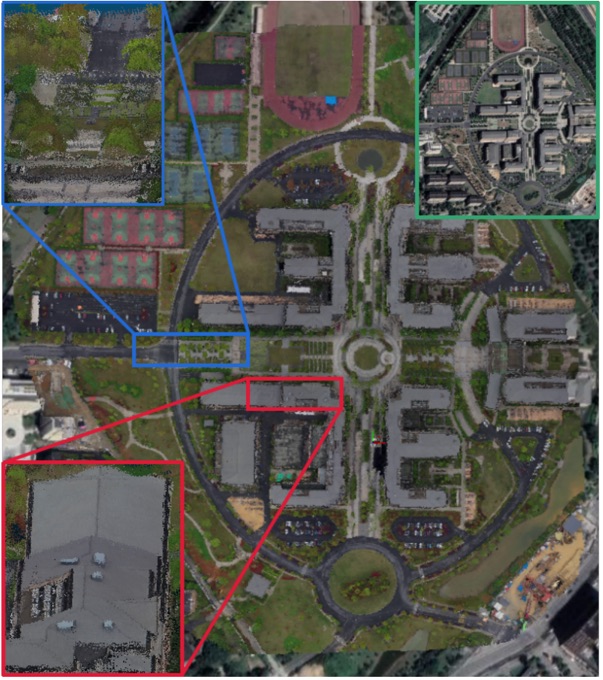
LODM large-scale UAV dense mapping result2022

LODM: Large-scale Online Dense Mapping for UAV

2022 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)

Jianxin Huang, Laijian Li, Xiangrui Zhao, Xiaolei Lang, Deye Zhu, and Yong Liu

This paper proposes an online large-scale dense mapping method for UAVs operating at altitudes of 150–250 meters.

Published 23 October 2022 · Dense mapping · UAV

Experience

Unitree Robotics logo
Mar 2025 – PresentUnitree RoboticsEmbodied AI Researcher
ZhuoYu Technology logo
May 2023 – Mar 2025ZhuoYu Technology(DJI Automotive)Perception Algorithm Engineer, Autonomous Driving

Education

Zhejiang University logo
2023Zhejiang UniversityM.Eng., Control Science and Engineering
Harbin Institute of Technology logo
2019Harbin Institute of TechnologyB.Eng., Automation